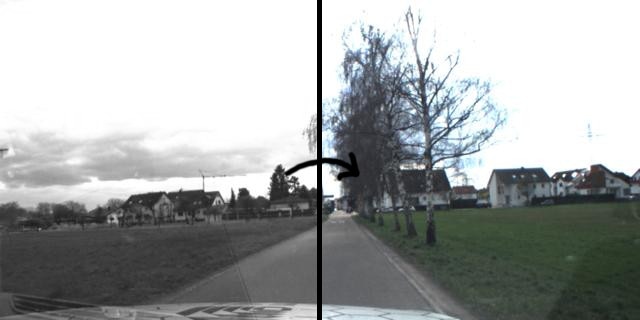
For the self-directed task of the lecture "Machine Learning 2", I implemented a U-Net in PyTorch to colorize grayscale driving scenes. It predicts the a and b chrominance channels in Lab color space, with the grayscale input supplying the L (lightness) channel.
The encoder-decoder architecture uses skip connections to preserve spatial detail. Debugging turned up two consequential mistakes that I fixed before the final run: I had taken the skip connections after max pooling, and unsorted filenames had misaligned predictions and targets during evaluation.
With learning-rate decay over 30 epochs, the model reached a validation loss of 5.77 MSE, the best result in class. The gap to second place was larger than the gaps among the other submissions. I saw no clear signs of overfitting during training. Both splits came from the same drive, though, so the similar training and validation distributions limit what this tells us about generalization to other scenes. I also received a perfect grade on the course exam.